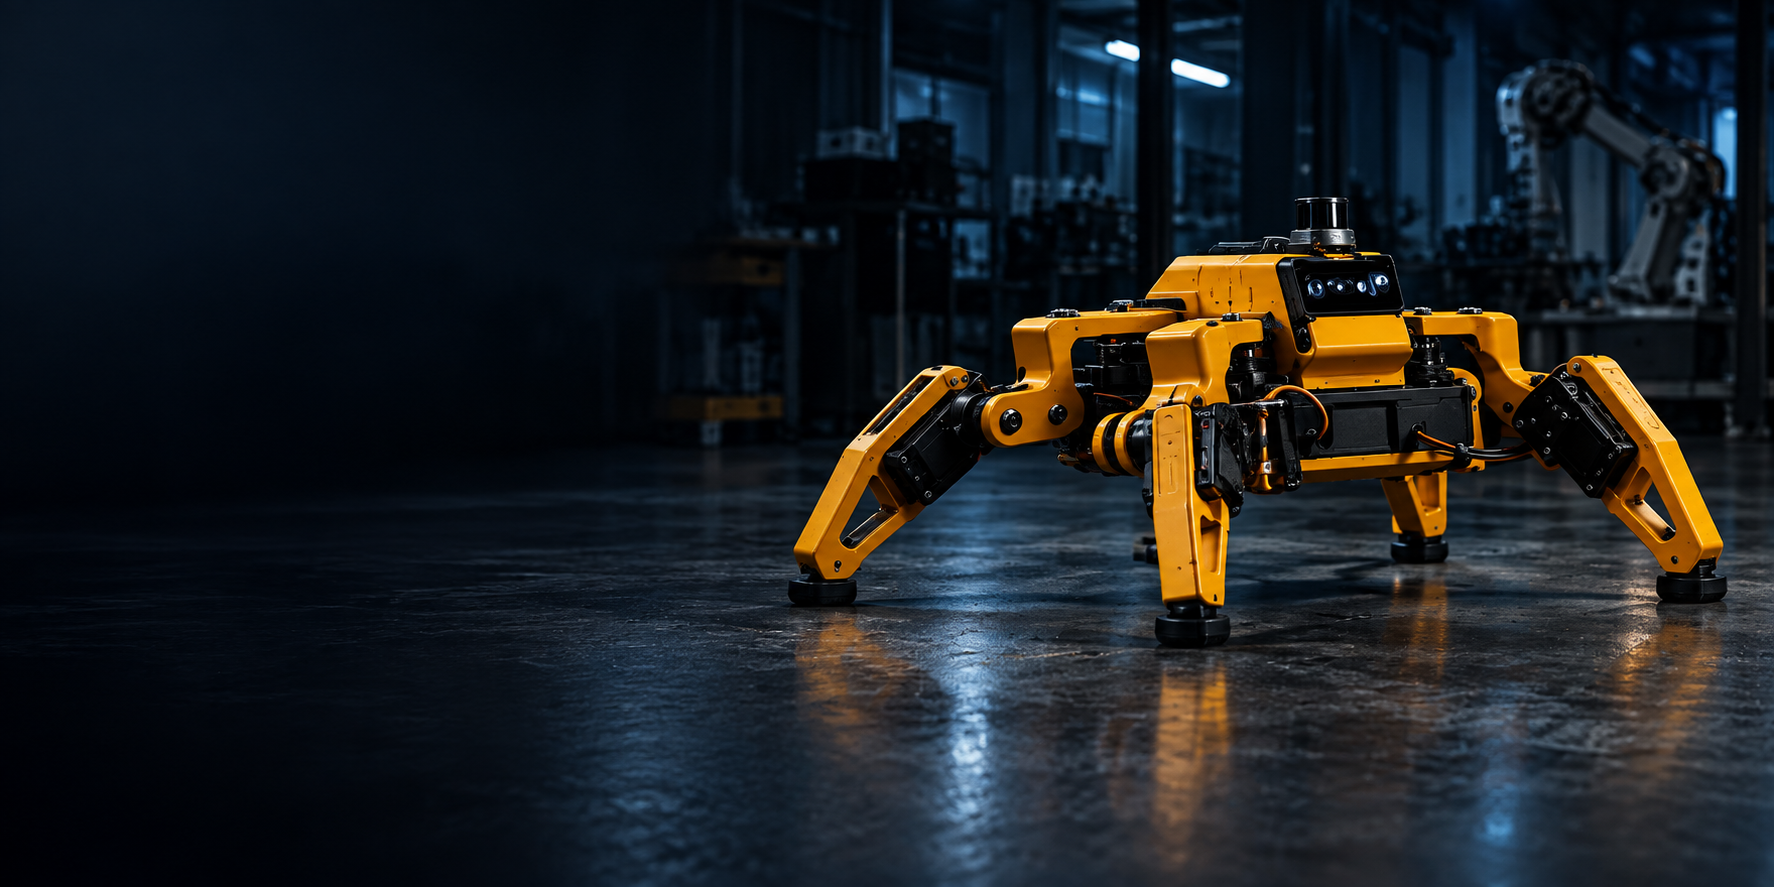
Spiderbot &
Legged Robotics
Compact robotic platforms for exploring locomotion, embedded intelligence, sensing and adaptive movement across non-standard terrain and constrained environments.
Interactive Terrain Adaptation Lab
Observe how multi-legged kinematics adapt to surface variations, adjusting stance elevation, leg extension, and body pitch to maintain continuous balance.
Select Terrain Profile
Switch ground topography to test adaptive locomotion gait and posture stabilization.
Biomimetic Gait Demonstration
Explore coordinated leg sequencing patterns that enable multi-legged robots to crawl, orient, and surmount steep angles.
Inside the Learning Loop
Legged robotics combines tight closed-loop sensory feedback with kinematic gait adaptation, forming an ideal platform for robotics education and embedded experimentation.
SENSE
IMU balance, current draw, and ground touch sensors collect state data.
PROCESS
Onboard microcontroller computes orientation tilt and body elevation.
PLAN
Inverse kinematic solver generates next foot coordinates and trajectory.
ACT
Servo bus executes coordinated PWM angle changes across all joints.
LEARN
Gait parameters adapt based on stability results and surface traction.
Embedded Systems
Hands-on exploration of real-time microcontrollers, serial communication protocols, and multi-channel PWM servo timing.
Gait Control & Kinematics
Study trigonometry-based inverse kinematics, wave gaits, and dynamic center-of-mass stability margins.
Programming & Research
Script behavioral logic, test reinforcement learning algorithms, and explore autonomous navigation with open-source toolchains.
Educational & Research Exploration
Compact multi-legged platforms deliver hands-on robotics understanding across educational classrooms and advanced laboratory testbeds.
STEM & Higher Education
Enables students to transition from theoretical mechanics to physical hardware debugging, covering motor drivers, sensor acquisition, and C++/Python robot control.
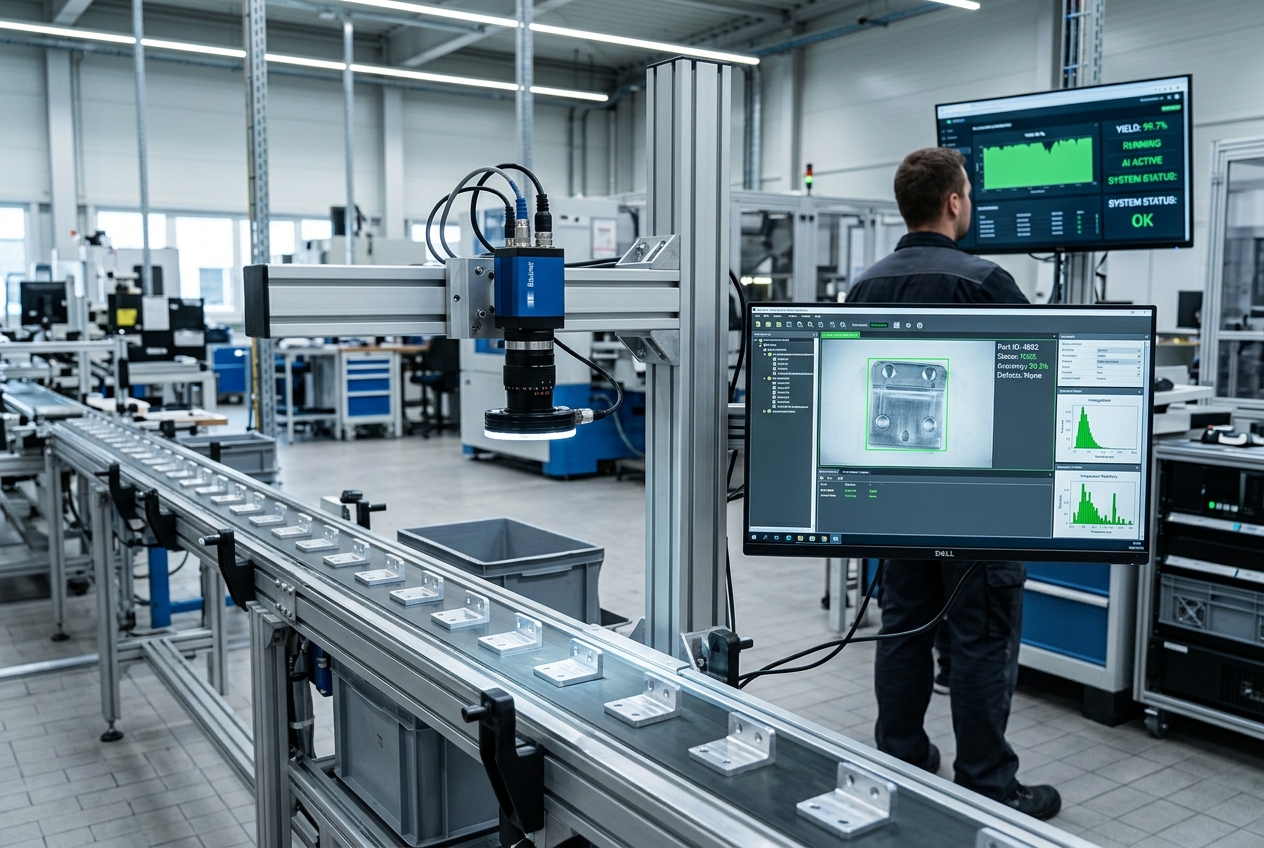
Locomotion Research
Offers university and corporate labs an accessible framework for evaluating adaptive foothold selection, neuromorphic control, and bio-inspired walking behaviors.
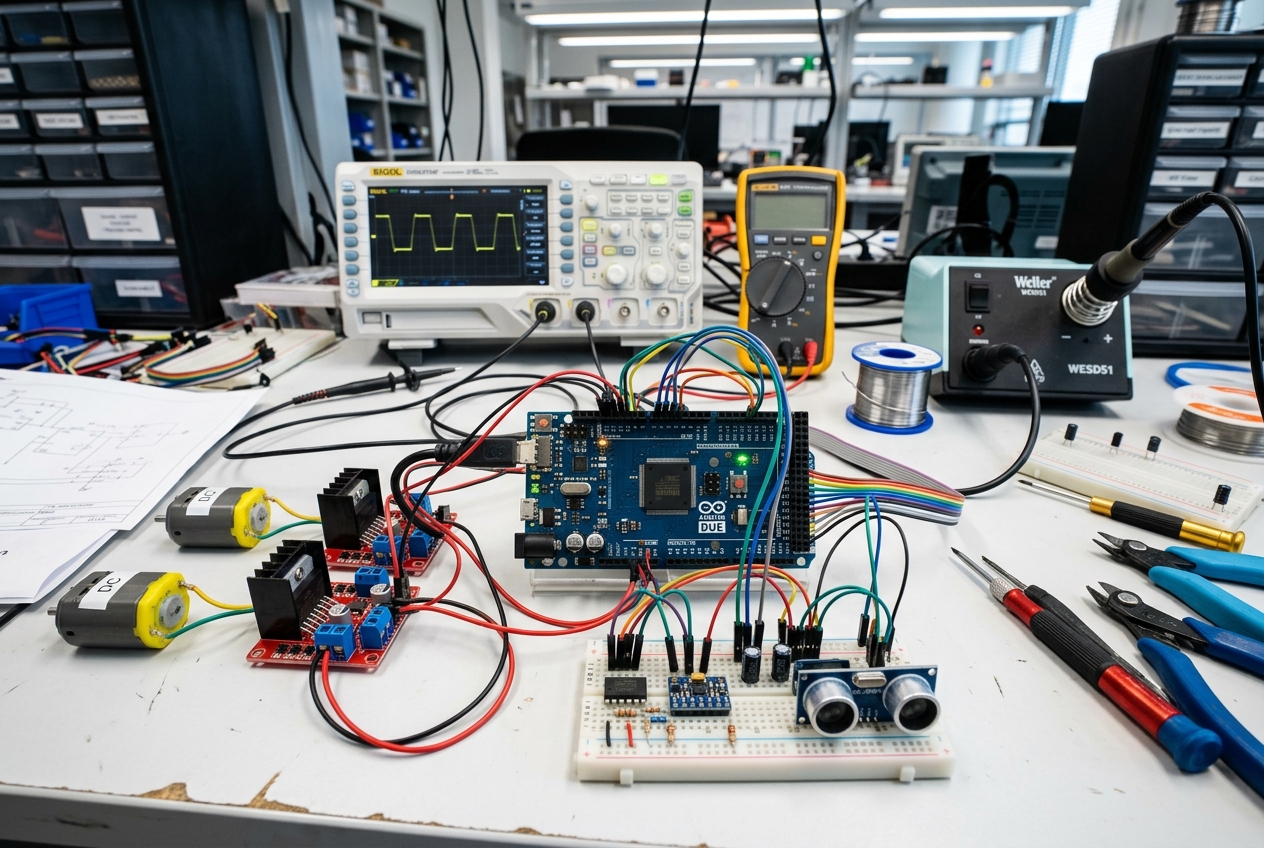
Rapid Concept Prototyping
Allows engineers to validate custom end-effector grippers, optical sensors, and payload delivery modules in compact physical test chambers.
Confined Space Exploration Concepts
Explores how low-profile legged chassis can negotiate pipes, rubble piles, and ducts where wheeled vehicles face mechanical entrapment.
Platform Mechanics & Electronics Stack
An overview of the biomimetic leg linkages, servo interconnects, and embedded compute framework.
Explore Legged Locomotion for Your
Academic Lab or Prototyping Program
Connect with our engineering and educational robotics team to discuss curriculum integration, research platforms, or custom development.