Robotic
Arms
Precision robotic systems engineered for controlled movement, handling, assembly, and practical industrial automation across modern manufacturing cells.
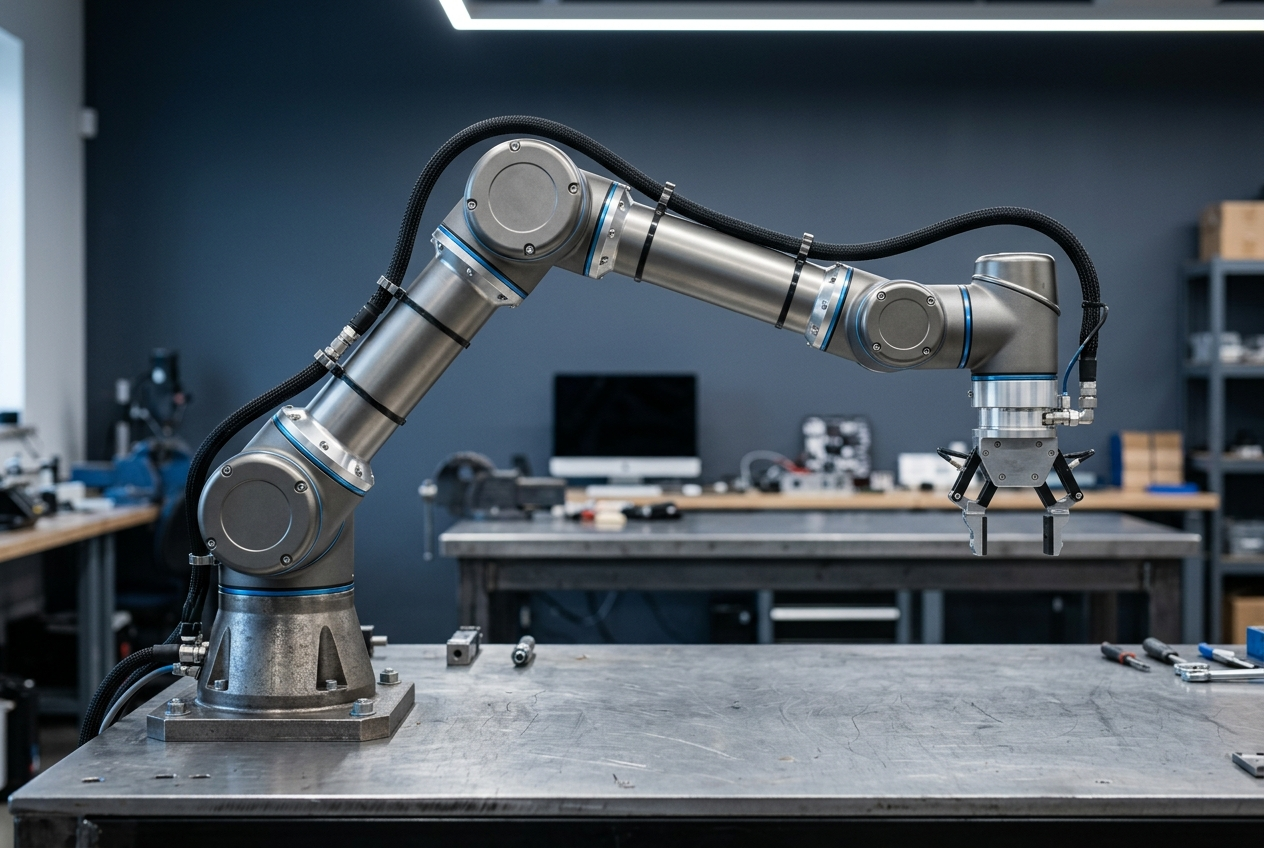
Interactive Multi-Axis Joint Inspector
Hover or click any joint pin (J1–J6) across the kinematic chain to inspect axis orientation, positioning roles, and degrees of freedom.
Base Rotation
Azimuthal base rotation orienting the arm structure across the workcell.
Pick-and-Place Task Simulation
Observe the coordinated cycle of a robotic pick-and-place sequence, executing precision path interpolation from component pickup to drop-off nest.
PICK
End-effector lowers over feeder station and engages workpiece.
MOVE
Arm lifts and traverses a smooth interpolated trajectory arc.
PLACE
Tool accurately positions component into target fixture nest.
RESET
Arm disengages and returns smoothly to home ready coordinate.
Engineering Pillars of Controlled Motion
Industrial articulated arms rely on coordinated kinematics, high repeatability, and flexible tool integration to maintain automation reliability.
PRECISION
Coordinated joint servo loops generate smooth velocity profiles, minimizing positional deviation during delicate handling tasks.
REPEATABILITY
Consistent cycle execution ensures identical component placement and fixture engagement across continuous shift operations.
END-EFFECTOR READY
Standardized wrist ISO flanges support rapid interchange of mechanical jaws, pneumatic suction cups, and custom magnetic grippers.
INTEGRATION
Seamless interface with industrial PLCs, vision systems, digital I/O lines, and safety interlocking protocols.
Target Workflows & Automation Scenarios
From precision parts placement to educational control labs, articulated manipulation systems support varied industrial tasks.
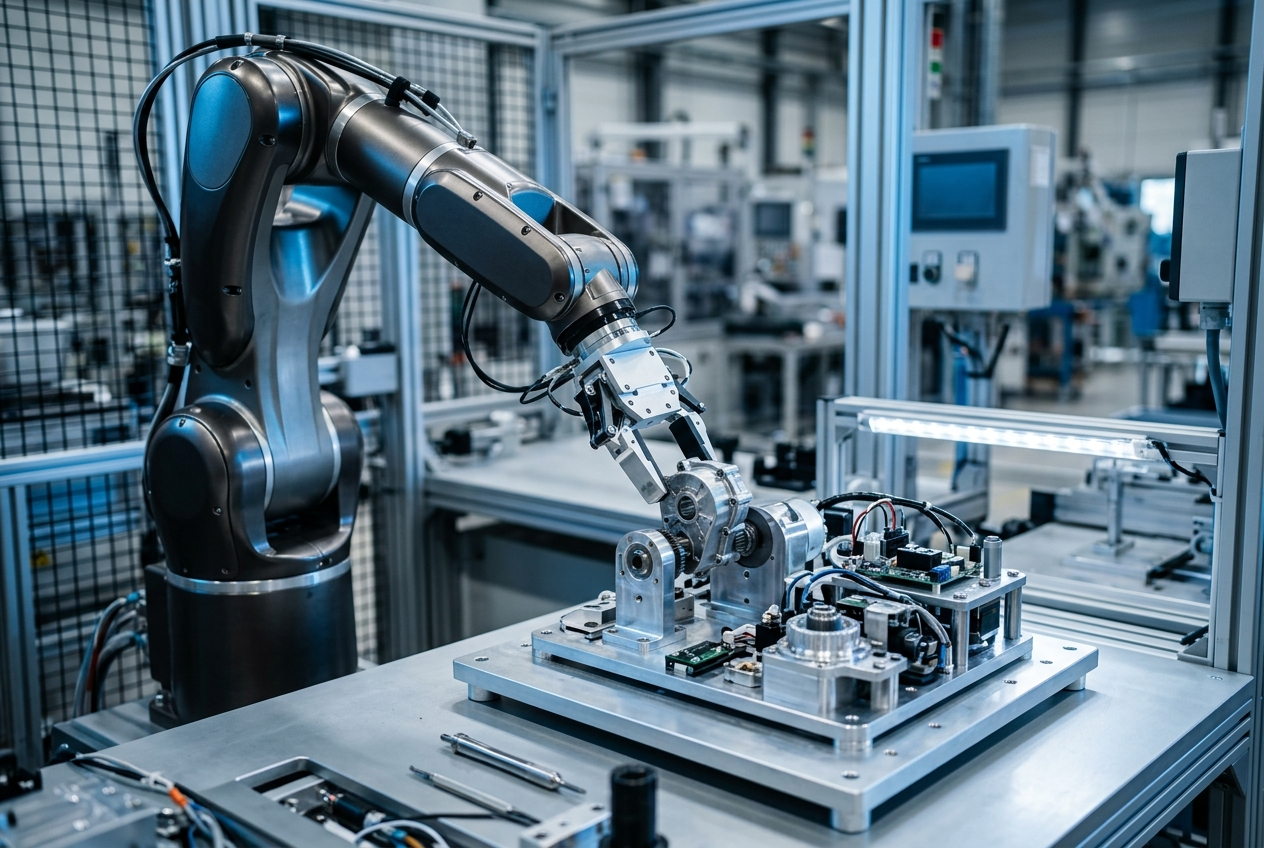
Component Assembly
Precision insertion, fastening, and alignment of multi-piece components with consistent orientation and controlled contact force.
Pick & Place Sorting
Rapid transfer of parts between trays, conveyor belts, and packaging blisters, reducing repetitive ergonomic strain.
Machine Tending
Automated loading and unloading of CNC mills, 3D printers, and test fixtures, enabling lights-out continuous cell operation.
Training & Robotics Education
Hands-on learning of inverse kinematics, trajectory programming, industrial safety zones, and Python/ROS robot control architectures.
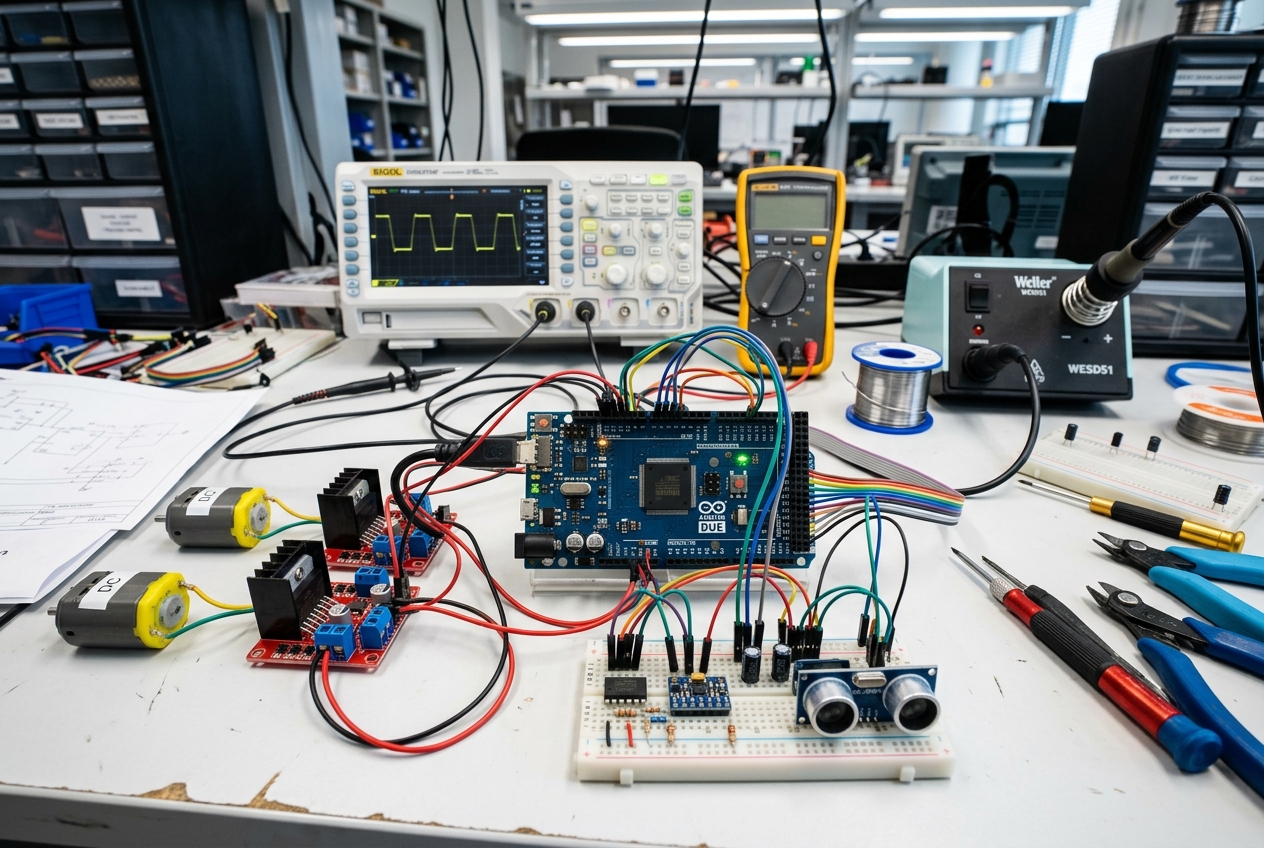
Rapid Prototyping
Flexible validation of end-of-arm tooling, custom pneumatic fixtures, and automated inspection concepts before scaling to production.
Kinematic Architecture & System Integration
An overview of the structural architecture, joint topology, and control interfaces supporting articulated manipulation.
Integrate Controlled Motion into Your
Next Generation Automation Cell
Discuss your pick-and-place, assembly, or robotics training requirements with our engineering team.